| 機器人也能自己爬樓梯掃地!電機系師生團隊,歷時半年研發製作「家用樓梯除塵機器人」-雷米度(Let Me Do),能自己上樓梯清掃,首次參加「全國微電腦應用系統設計製作競賽」,在大專組與研究所組第一名都從缺下,榮獲大專組「機器人與自動機具類」第二名。 |
Saturday, November 28, 2009


Thursday, November 12, 2009
Robot comes to aid of fire crew at depot blaze

Firefighters enlisted the help of a robot to dramatically reduce the time spent dealing with a fire at a Wokingham industrial estate.
Royal Berkshire Fire and Rescue Service used the Remotely Operated Vehicle (ROV) to handle the acetylene cylinder at Toutley Depot in Old Forest Road, which had caught fire while a worker used it for welding.
Standard operational procedure would have meant a 200-metre cordon being set up for 24 hours, which would have meant closing Toutley Depot, the A329 and evacuating some residents.
The fire crew was called to the incident at 12.45pm on Thursday, September 24.
By sending the ROV into the workshop the crews could receive vital information about the incident without putting themselves in danger.
The ROV has in-built specialist tools, including a thermal imaging camera and filming equipment, which allows firefighters to assess the situation from a safe distance.
The ROV found the cylinder was cool and operators then turned off the valve using a spanner attached to the robot.
Station manager Jess James, from Caversham Road station, said: “Using the ROV meant that we could deal with the incident in around three-and-a-half hours, rather than the 24 hours it would traditionally take.
“This not only means that the premises could be handed back to the owners in a shorter space of time, but also that fire crews are freed up more quickly and are available to attend other incidents.”
http://www.getwokingham.co.uk/news/s/2058394_robot_comes_to_aid_of_fire_crew_at_depot_blaze
中華電信一號 減火機器人
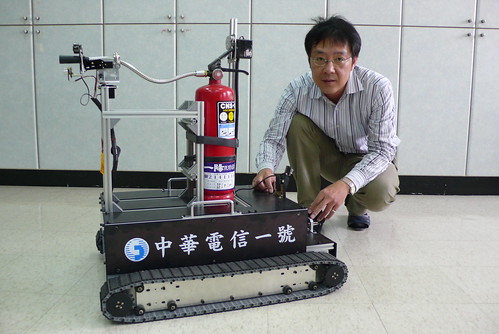
中華電信一號 減火機器人
中華電信一號 減火機器人記者陳美文/南市報導
中華電信台南營運處規劃設計科楊佳璋成功開發出「中華電信一號」,這是國內第一部透過網際網路防災滅火的機器人,可搭載三至廿磅不同廠牌尺寸的滅火器,在火勢尚未釀成大災難或消防人員未抵現場前先撲滅火勢,並將全程錄影救火過程,作為追查線索研判肇事主因。
楊佳璋表示,目前坊間所有的災害監控系統,都是透過定點式監視器來監看現場,「中華電信一號」防護機器人,可從相距數百公里甚至更遠的監控中心,以網頁作為人機介面操控中華電信一號,再利用中華電信一號上的影像設備,傳回毫無時差的火場現況。
換言之,監控人員只要坐在監控中心,透過網路就可指揮機器人進行救災工作,而且機器人在滅火後可由監控中心人員操控回定點自動充電,不用再派人員到現場充電或更換電池。
除了工地監控,災難現場救援之外,具有「移動性的動態視訊」特性的中華電信一號,也適用於居家老人看護的應用,由於居家老人的狀況多,不管在哪個角落,中華電信一號都可以發揮靈活的移動監視功能,確實掌握現場狀況。
中華電信這項創新的研究成果,預計將於五月在台南市舉辦中華電信全區防火防災演習中正式發表,宣導更新的科技生活概念。
Tuesday, November 10, 2009
[New Book] Visual Servoing Control Based Three-Dimensional Tracking: Theory, Algorithms, Practicalities

Visual Servoing Control Based Three-Dimensional Tracking: Theory, Algorithms, Practicalities (Paperback), Chao-Ching Ho (Author)
Language: English
ISBN-10: 3838305353
ISBN-13: 978-3838305356
Product Dimensions: 8.7 x 5.9 x 0.2 inches
Find it on Amazon, or Books on Demand.
Sunday, October 25, 2009
Tuesday, October 06, 2009
從SPIE Optics and Photonics 2009探討數位光學及3D影像處理技術
TOF Camera近年又被稱為3D Camera,屬於一種Depth-sensing技術,此種Camera利用主動式照明對待測場景發射一參考光束,藉由計算回光的時間差或相位差來換算 場景中物體的距離,並產生一深度地圖資訊(Depth Map)。一般來說,會有另一組傳統的Camera拍攝該場景,以同時獲得二維影像與第三維的深度資訊。
詳細資料 -> http://www.materialsnet.com.tw/DocView.aspx?id=8108
詳細資料 -> http://www.materialsnet.com.tw/DocView.aspx?id=8108
Friday, September 11, 2009
OpenCV 1.2 beta, the installation package for Windows
- CXCORE now uses Lapack (CLapack 3.1.1.1 in OpenCV 2.0) in its various linear algebra functions (such as solve, invert, SVD, determinant, eigen etc.) and the corresponding old-style functions (cvSolve, cvInvert etc.)
- FAST - the fast corner detector, submitted by Edward Rosten
- LDetector - fast circle-based feature detector by V. Lepetit
- Added dense optical flow estimation function
- Most of the new linear and non-linear filtering operations
- There is now uniform interface for capturing video from two-, three- ... n-head cameras.
Monday, August 31, 2009
Friday, August 28, 2009
Robot fish (機器魚) Introduction
Robotics Department at the University of Essex by Prof. Huosheng Hu
NHK video of Japanese robot fish
[Reference] http://www.robotic-fish.net/
- 於西班牙Gijon水質監控 (西班牙北方的海域中,用來研究海裡的污染程度)
- 測試水中溶氧量,
- 偵測河中的原油洩漏或其他汙染源,
- 機械魚就會游到河表面並無線傳輸(透過WiFi)將資料送到港口控制中心,
- 機械魚電池電力將近用罄時,它就會導航游回電力站充電,
- 可以模仿真實魚群的游行模式,
- 造價約美金29,000,
- Keynote speech on 2009 IEEE International Conference on Electronic Measurement & Instruments 。
NHK video of Japanese robot fish
[Reference] http://www.robotic-fish.net/
Wednesday, August 26, 2009
[EM330] How to convert PWM signal to DAC voltage?
[Purpose]

2. 使用OP +RC。

[Reference]
當你想要控制馬達Driver的速度時,你需要輸入0~5V的訊號給Driver(電壓愈高,馬達轉愈快),可是PIC16或PIC18只有PWM信號輸出,沒有低速的DAC (高速的DAC須外掛 SPI , I2C等界面的晶片)?
[Solution]- 使用R-2R電阻電路,如圖,最簡單。
Tuesday, August 11, 2009
Sunday, July 26, 2009
桌上型機器人鎖螺絲機 精度高
可台公司新推出桌上型機器人鎖螺絲機,擁有多項特點,使用XY TABLE鎖付螺絲,精度高,操作簡單,採用液晶教導盒操作,可視XY座標數值,程式記錄容量大,至少可存99組,每組4,000點,重覆精度高 (±0.02mm),鎖付範圍內(300×300mm),可同時擺放多個工件,且一位工作人員可同時操作多台鎖付機,採用氣吹式,將螺絲吹至夾頭前端,可 以迅速鎖付,無需浪費其他位移時間,因為沒有回程吸取螺絲,所以比氣吸方式快1倍鎖付時間以上,並具有滑牙檢知功能,所以可以檢知螺絲是否鎖付完成,該機 台為投資最少,效率最高,回收最快,鎖付螺絲的利器。
工商時報【台中訊】
Friday, July 03, 2009
Thursday, July 02, 2009
[Robotics & Machine Learning] New analytical science findings from C.C. Ho and co-authors described
Robotics & Machine Learning
New analytical science findings from C.C. Ho and co-authors described
2009 APR 20 - (VerticalNews.com) -- According to a study from Taiwan, "This paper proposes a novel real-time machine video-based flame and smoke detection method that can be incorporated with a surveillance system for early alerts. Automatic monitoring systems use the motion history detection algorithm to register the possible flame and smoke position in a video and then analyze the spectral, spatial and temporal characteristics of the flame and smoke regions in the image sequences."
"The spectral probability density is represented by comparing the flame and smoke color histogram model, where HSI color spaces are used. The spatial probability density is represented by computing the flame and smoke turbulent phenomena with the relation of perimeter and area. Statistical distribution of the spectral and spatial probability density is weighted with the fuzzy reasoning system to give the potential flame and smoke candidate region. The temporal probability density is represented by extracting the flickering area with level crossing and separating the alias objects from the flame and smoke region. Then, the continuously adaptive mean shift (CAMSHIFT) vision tracking algorithm is employed to provide feedback of the flame and smoke real-time position at a high frame rate," wrote C.C. Ho and colleagues.
The researchers concluded: "Experimental results under a variety of conditions show that the proposed method is capable of detecting flame and smoke reliably."
Ho and colleagues published their study in Measurement Science & Technology (Machine vision-based real-time early flame and smoke detection. Measurement Science & Technology, 2009;20(4):45502).
For more information, contact C.C. Ho, National Yunlin University Science & Technology, Dept. of Mech Engineering, Yunlin 64002, Taiwan.
Publisher contact information for the journal Measurement Science & Technology is: IOP Publishing Ltd., Dirac House, Temple Back, Bristol BS1 6BE, England.
Keywords: Emerging Technologies, Fuzzy Logic, Machine Learning, Machine Vision, Measurement Science.
This article was prepared by VerticalNews Robotics & Machine Learning editors from staff and other reports. Copyright 2009, VerticalNews Robotics & Machine Learning via VerticalNews.com.Monday, June 22, 2009
How to open comport COM10 and above in WINDOWS XP
Details
Solution
For the moment, ports above COM10 are not named COM10. They are named \\.\COM10 and so on. Except that some drivers use names like USB port 1 for all ports. Don't forget to double \ chars when inside quotes. E.g. "\\\\.\\COM10"
Manually edit the virtual machine's configuration file (.vmx on Windows hosts, .cfg on Linux hosts). Change the following line from:
serial0.fileName = "COM10"to
serial0.fileName = "\\.\COM10"Power on the virtual machine to verify the COM10 serial port is operational.
Sunday, June 14, 2009


Subscribe to:
Posts (Atom)
